The moment you know something is wrong
You designed the contacts in CAD. Light, even, right where you wanted them.
You exported the STL. The print came out clean: base, teeth, supports snapped off without a fight. You mounted the model on the articulator. You closed it.
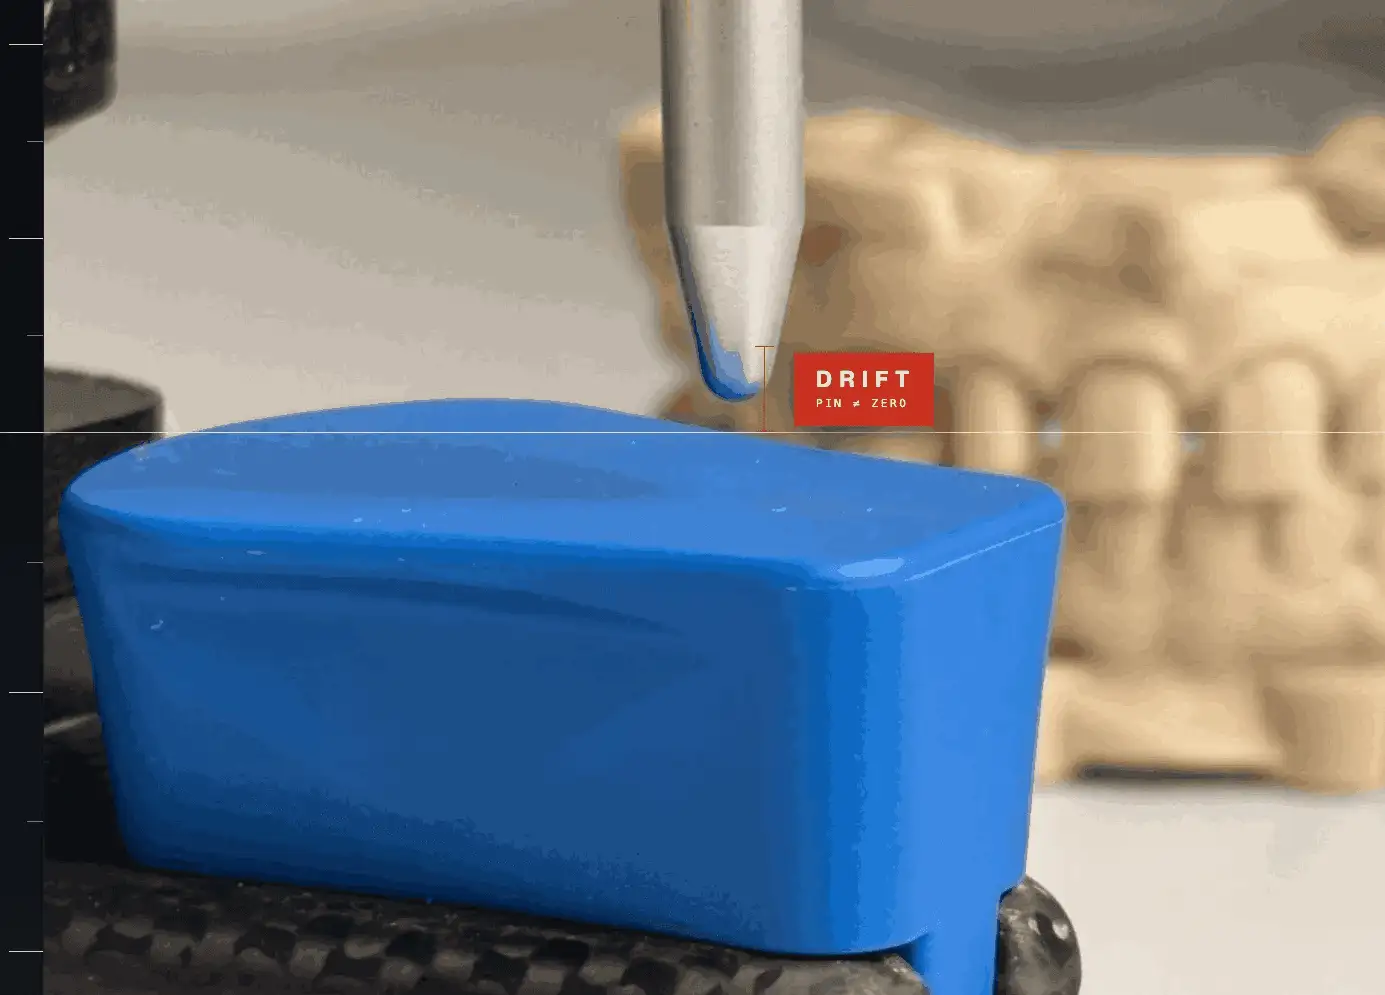
And the pin didn’t return to zero.
You open it. You check the contacts. Some are there. Some are missing. Some are in places you never put them. The match between what’s on your screen and what’s on your bench is gone, and you don’t know why.
So you start the loop. You check the scan. The scan is fine. You check the print. Dimensions look right. You check the bite registration. Correct. You check the articulator. It seems fine. You re-mount the model. Same result. Maybe slightly different. That’s worse.
Now the doubt begins. Is it the resin? The printer? The CAD design? The articulator? Is it me?
Every digital lab lives this scenario. Every week. Sometimes every day. It costs time, materials and, quietly, slowly, confidence in the entire workflow you spent years and tens of thousands of euros building.
And until today, the problem didn’t even have a name.
It does now.
It’s called transfer drift.
What transfer drift actually is
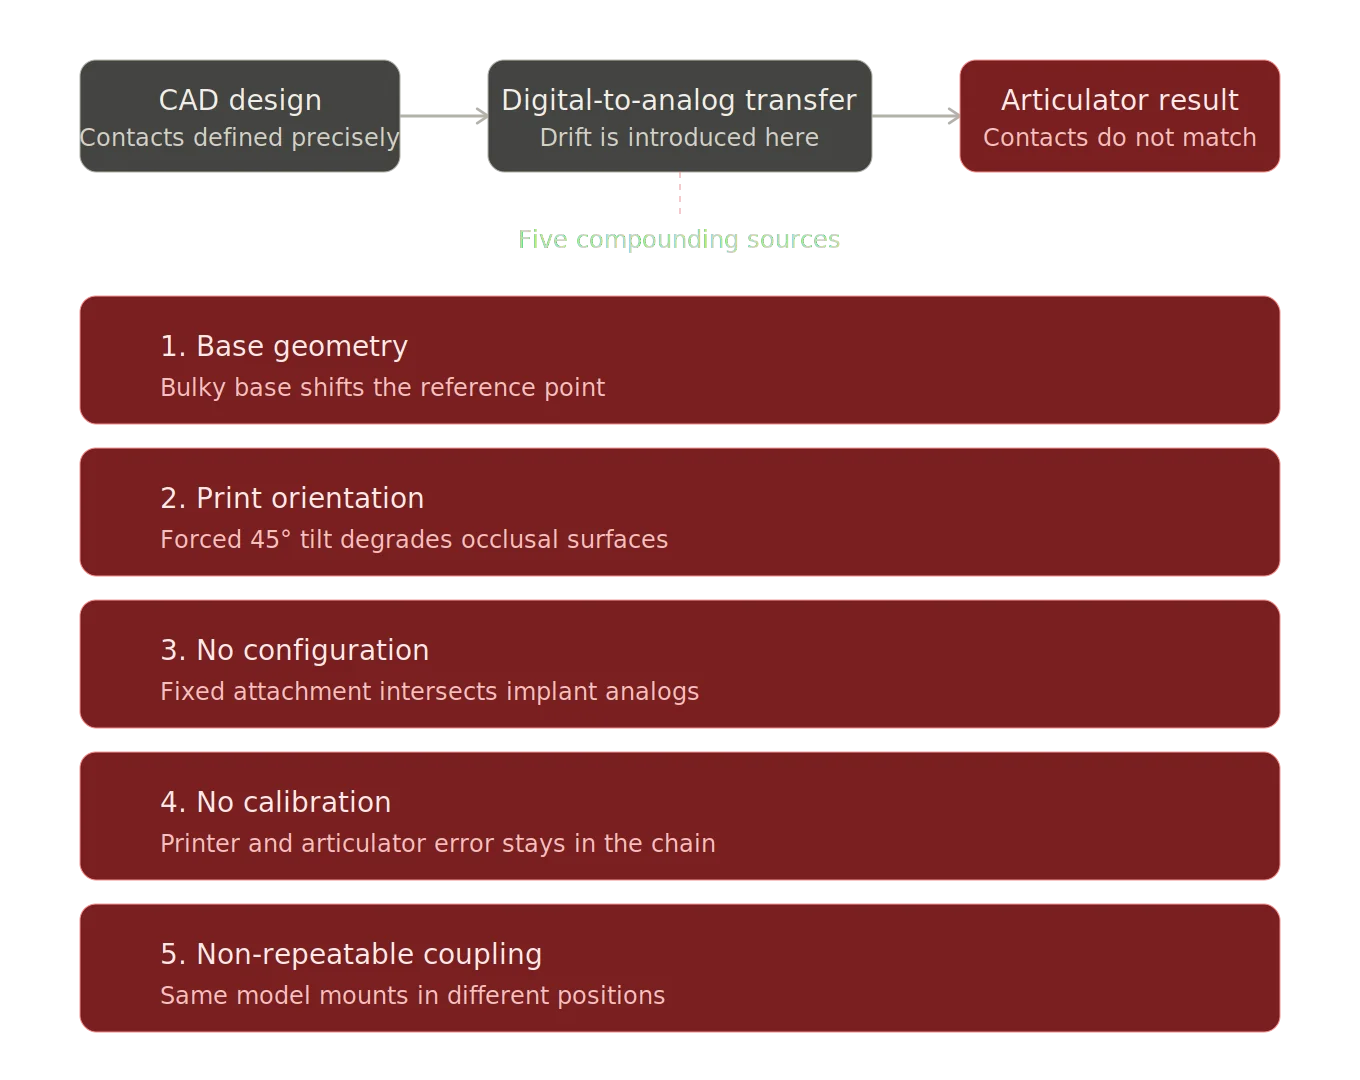
Transfer drift is the cumulative positional deviation that occurs when a 3D-printed model is transferred from the digital design environment to a physical articulator.
It is not one error. It is the sum of several uncontrolled variables that compound at the moment digital becomes analog: the handoff. Each one is small. Together, they’re the reason your contacts don’t match.
There are five sources:
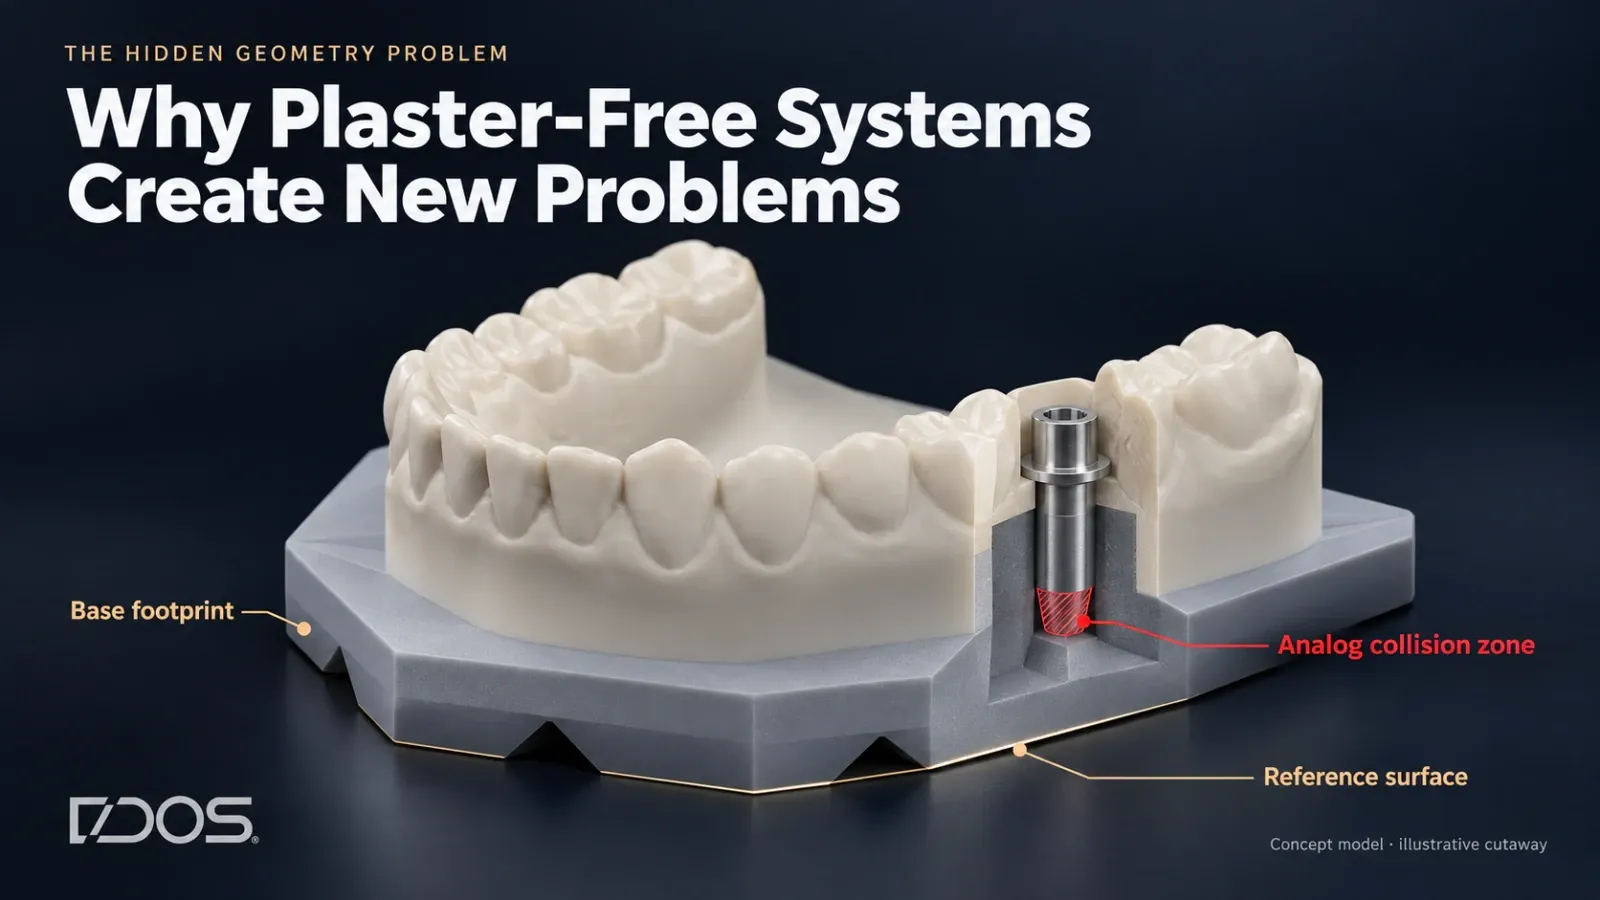
- Base geometry that shifts the reference point. The mounting base of most plaster-free systems is bulky enough to introduce its own coordinate offset. The position your CAD software defines is not the position the articulator sees.
- Forced print orientation. When the base geometry is too large to print flat, the model gets rotated to 45° (or worse). Print height increases. Layer artefacts shift to the occlusal surfaces. Teeth, which print best horizontally, lose definition right where definition matters most.
- No modular configuration. A single fixed attachment can’t adapt to case-specific anatomy. On implant cases, the base physically intersects with analogs. You compromise the design to fit the system, not the other way around.
- No calibration. Every printer has a Z-axis drift. Every resin behaves slightly differently. Every articulator has its own mechanical tolerance. None of these are factored in. The system assumes every printer, resin and articulator behaves the same. None of them do.
- Non-repeatable magnetic coupling. Mount the same model twice and you get two slightly different positions. Without a defined reference, “repeatability” is a marketing word, not a measurement.
Every step after “export STL” introduces drift. Nobody measures it. Nobody specifies it. Nobody takes responsibility for it.
That’s the problem.
Why plaster-free systems make it worse
The plaster-free category solved the wrong problem.
Yes, plaster is slow. Yes, plaster is messy. Yes, plaster is the part of the workflow nobody misses. But plaster, for all its faults, did one thing exceptionally well: it created a rigid, custom-fit interface between the model and the articulator. The plaster molded itself to the unique geometry of your case. The reference point was the case itself.
Magnetic plaster-free systems replaced that custom-fit interface with a standardized one, and in doing so, they traded one problem for four new ones:
- Bulky bases that physically intersect with implant analogs. On the cases that matter most (full arches, multiple implants, complex restorations) the base itself is the obstacle. You can’t even use the system. Or worse, you use it and force a compromise into the design.
- Base geometries so large they force 45° print orientation. What you save on plaster, you pay back in print time. And the teeth, which should be printed horizontally for the best surface detail, come out worse than the model you used to make from a stone cast.
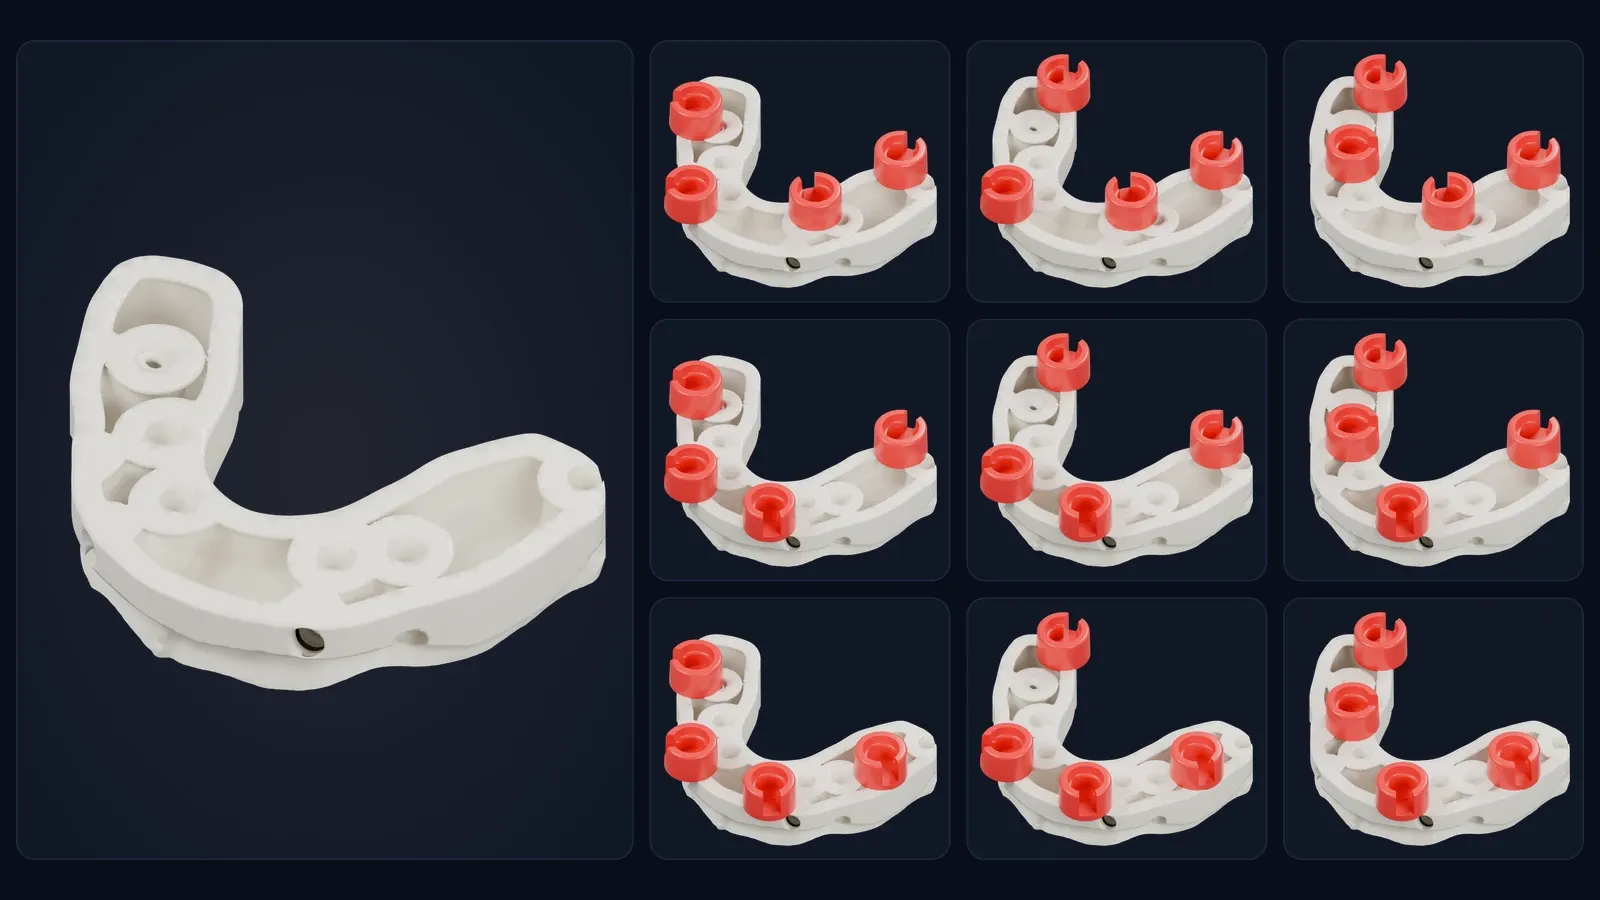
- No modular configuration. One geometry. One attachment pattern. Take it or leave it. The system doesn’t adapt to your case. Your case adapts to the system.
- No calibration for your printer or your articulator. The factory assumes an ideal world. You don’t work in an ideal world. You work in your lab, with your specific printer, your specific resin and your specific articulator, and the system has nothing to say about any of them.
You’re not eliminating error. You’re eliminating plaster, and replacing it with four new sources of error you can’t see, can’t measure and can’t fix.
That is transfer drift. Engineered into the very systems that promised to solve it.
The cost of invisible error
Transfer drift is invisible only until you count it.
Every time the contacts don’t match what you designed, one of three things happens:
- You recheck. Every case where doubt creeps in costs you bench time you never bill, and the math gets ugly fast.
- You adjust on the bench. Faster, but every grind is a compromise of the digital design you spent time refining in CAD. You’re correcting analog with analog, undoing the precision you paid for.
- You remake. The case comes back from the practice for an adjustment that should never have been needed. Materials, time and the most expensive cost of all: your credibility with the dentist.
On a single-unit case, the cost is annoying. On a full-arch implant case worth thousands, an uncontrolled transfer is a financial event. The case comes back. The lab eats the remake. The relationship with the practice cools.
Now scale it, with an example.
Say your lab runs 10 cases a day, 250 working days a year: 2,500 cases. Say transfer drift costs you ten minutes on a quarter of them. That’s over 100 hours a year, more than two full working weeks, spent fixing an invisible error nobody warned you about.
Transfer drift isn’t a precision problem. It’s a productivity drain, a margin killer and, quietly, over years, a confidence problem that makes you wonder if digital was the right move at all.
It was. The transfer system was the wrong move.
See what labs say in their reviews
Why nobody named it before
There’s a reason transfer drift doesn’t exist as a recognised category in the dental lab world: most of the category fights the same commodity war.
Plaster-free. Fast. Compatible. Clean.
Four words. The same pitch everywhere. When everyone says the same thing, nobody says anything, and the real problem stays invisible.
The real problem, the gap between what you design and what you verify, was never named because naming it would mean admitting that “plaster-free” alone doesn’t solve it. It would mean admitting that the systems built to fix one workflow problem quietly introduced four worse ones.
So the problem stayed nameless. Technicians blamed themselves, blamed their printers, blamed their resin, blamed their articulators. They blamed everything except the system standing between them and a verified result.
DACOS names it: transfer drift.
And then DACOS solves it.
See how ZeroDrift™ Transfer takes the transfer out of your error chain
The Transfer Fidelity System engineered so the contacts you design in CAD are the contacts you verify on the articulator.
Patent Pending. The DACOS Omni system, including its adapter plates, calibration method, attachment geometry and magnet placement tools, is protected by a pending international patent application.